Lucid Computing
Infrastructure and Software Engineer Intern, May to August 2026
Built a heterogeneous 16-GPU cluster (H100 and A100) under one Slurm-on-Kubernetes scheduler, plus its CI/CD pipeline. Deployment is reproducible through GitOps: a separate dev cluster came up from the same declarative config with no manual setup.
stack: Kubernetes, Slurm, FastAPI, PostgreSQL, vLLM, GitHub Actions, React
more
- Shipped researcher-facing platform: a FastAPI control plane as the cluster single provisioning and audit path across Slurm, LDAP, NFS, and Kubernetes, and a React console for self-serve GPU provisioning, SSH access, and role-based access.
- Served Qwen3.5-397B-A17B tensor-parallel across 8× H100, maintained as code and guarded by a CI smoke test that tells real regressions from a busy cluster.
- Set up CI/CD with tag-triggered deploys and rolling updates on self-hosted runners inside the air-gapped cluster, with rollout verification, version pinning, and an self-hosted LLM-based PR review gate before production.
Trilobio
Three internships, 2024 to 2026
Robotics Engineer Intern Jan to Mar 2026
Model predictive control for robotic-arm motion planning: no overshoot, about 2× faster settling, and 96–99.7% lower steady-state error.
stack: Model Predictive Control, MuJoCo, Python, C++, Optimization
more
- Stood up a MuJoCo simulation environment to validate control algorithms before deploying to hardware.
- Benchmarked latency, stability, and computational load to assess real-time MPC on embedded hardware.
Software Engineer Intern Jun to Aug 2025
Building software for robotic lab-automation platform, to run biology protocols on the robot: multichannel pipetting, cross-contamination modeling, and labware layout.
stack: TypeScript, Python, Google OR-Tools, constraint programming
more
- Prototyped an auto-layout engine using constraint programming (Python, Google OR-Tools, custom solvers) that replaced hours of biologists’ daily manual protocol planning.
- Deployed multichannel and multidispense pipetting optimization in TypeScript, with transformation-matrix rotation planning for the arm. Parallel operations made lab protocols ~6× faster.
- Implemented a contamination-modeling algorithm that prevents cross-contamination and cut consumable waste by 30%.
Robotics Engineer Intern May to Aug 2024
Prototyped the first camera system for Trilobio robot arm, with no vision sensing before, end to end across mechanical, electrical, and software engineering.
stack: OpenCV, PCB design, firmware, CAD, CAN, USB 2.0, Oscilloscope
more
- Implemented OpenCV laser-triangulation pipeline that produces 3D point clouds and surface meshes, using custom camera and laser mounts designed in CAD.
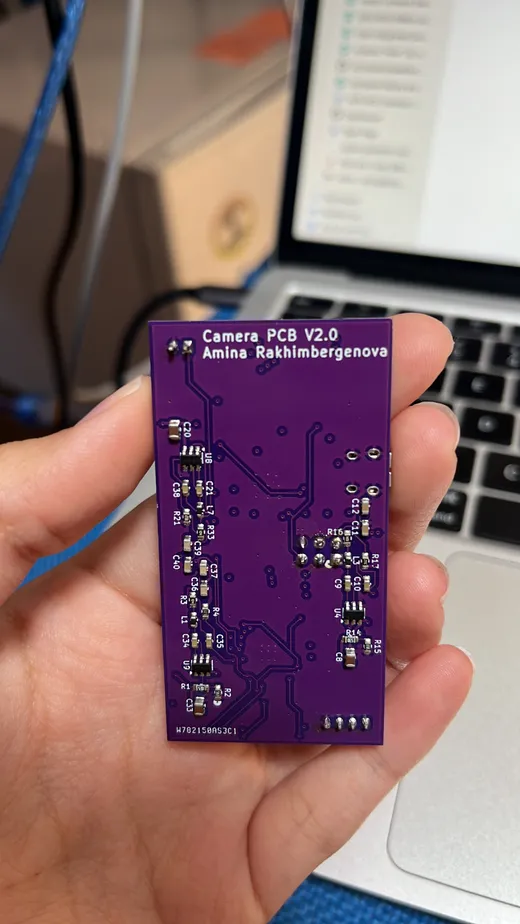
- Engineered and debugged custom USB hub PCBs and firmware for high-throughput sensor streaming.
- Moved the robot’s communication stack from CAN (8 Mbps) to USB 2.0 High-Speed (480 Mbps), debugging and validating signal integrity with an oscilloscope and test fixtures.
Earlier
AI research engineering at Jubo Health: a real-time healthcare analytics endpoint over medical records, demoed at the Healthcare+ EXPO. Software engineering at Brothers On The Rise: a web app that automates user-feedback processing.